



More Information
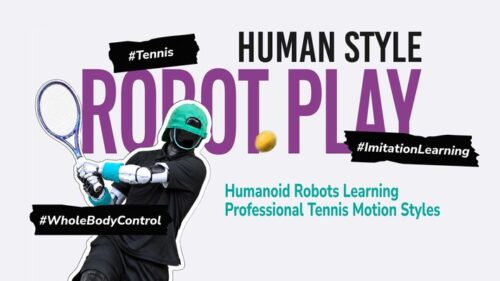
Humanoid robots have begun to show real capability in ball sports, but preserving a professional athlete’s motion style while maintaining reliable task performance is still an unresolved problem. This guide examines an adaptive motion planning and tracking framework that learns tennis serving and rally styles directly from broadcast video and motion-capture data. A hierarchical design separates a planner, which generates stylistic kinematic motion, from a tracker, which executes that motion with minimal interference. Because tracking performance inevitably degrades when a policy trained in simulation moves to physical hardware, the framework trains its tracker on randomized execution speeds and conditions its planner on a learned motion-speed representation, reducing the compounding errors introduced by autoregressive planning and noisy perception. The paper documents real-world validation on a research humanoid platform and transfer to a full-size humanoid robot, including serving in an uncontrolled environment without motion capture, and closes with practical, transferable lessons for engineers building future humanoid ball-sports systems.


